Puntey Automatic Car
Autonomous obstacle-navigating robotic vehicle platform
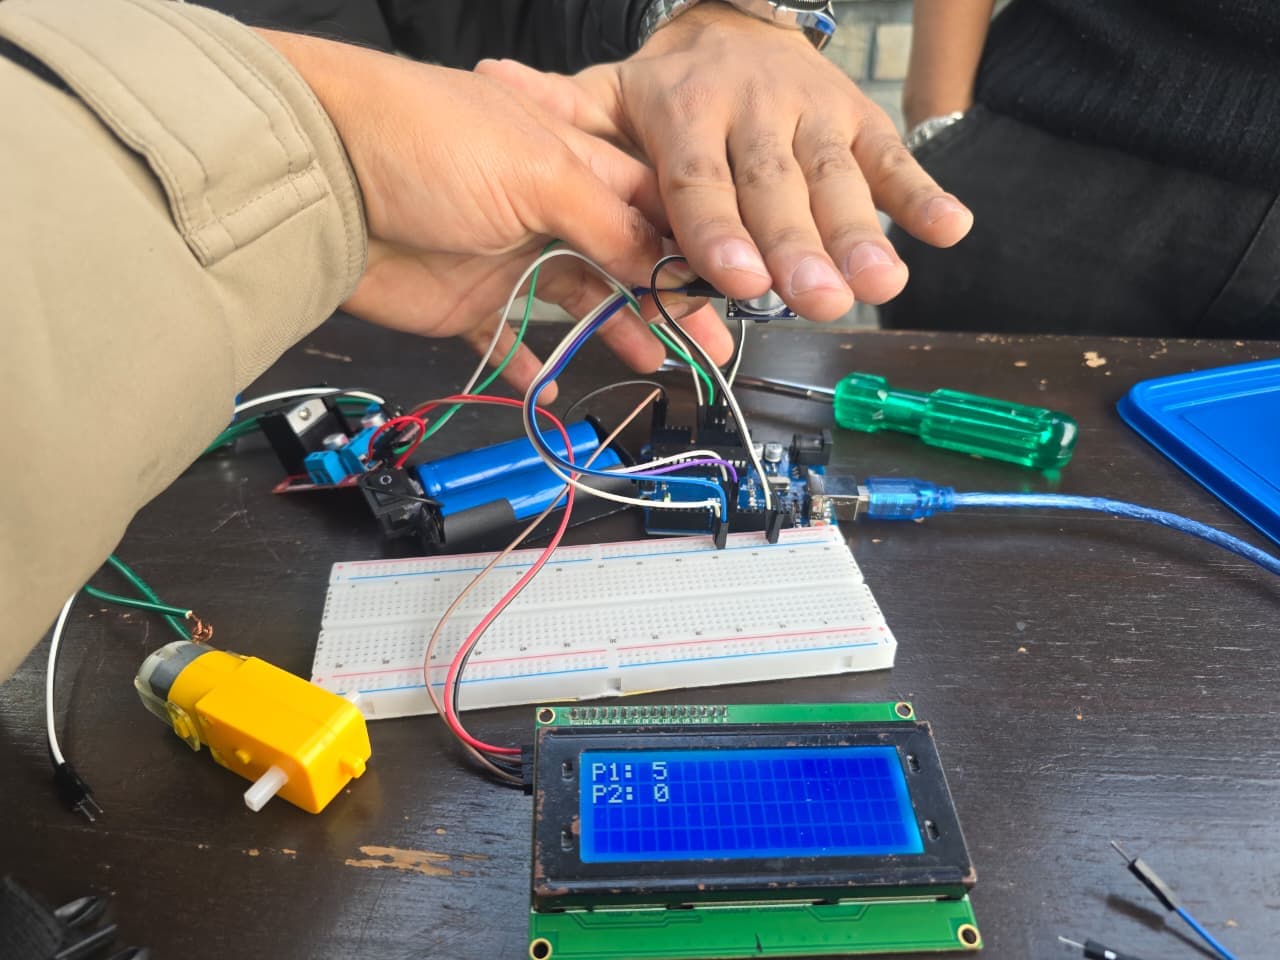
A microcontroller-guided robotic vehicle featuring real-time ultrasonic ranging, adaptive steering algorithms, and onboard battery regulation for autonomous obstacle avoidance.
The Puntey Automatic Car is a student-built autonomous robotic rover designed to experiment with real-time obstacle avoidance, sensor fusion, and motor control kinematics.
Constructed on a custom chassis with four-wheel differential drive, the vehicle continuously scans its forward hemisphere using ultrasonic distance sensors. When an obstacle is detected within threshold distances, an onboard navigation routine calculates clearance vectors and commands the motor drivers to pivot and clear a path.
The vehicle incorporates a dedicated power management circuit to isolate motor inductive spikes from delicate microcontroller logic, ensuring smooth autonomous navigation across diverse indoor surfaces.
- Fully student-engineered mechanical chassis and electrical power distribution
- Autonomous navigation without external compute or remote intervention
- Neo Spark Autonomous Systems GuildRobotics Research & Obstacle Avoidance
- Neo Spark Embedded Firmware CollectiveSensor Fusion & Motor Control
Gym Management System
Streamlined member tracking, subscription billing, and gym operations